When one team replaces several disconnected Analytics, Engineering, and Robotics Companies
Have you ever seen a great project drown in endless approvals between departments and multiple contractors? We have our own solution.
We’re a compact and agile team of engineers, industrial designers, electronics experts, and software developers.
But it’s precisely our compact size and the multidisciplinary expertise of our team that allows us to create technical solutions and MVPs in the shortest possible time.

What Engineering and Product Development services do we offer?
We provide a full range of services for building robots and robotic systems — from analyzing market needs and identifying new product ideas, to manufacturing and testing pre-production prototypes.
There is only one restriction: the project topic must align with our main areas of expertise, which are presented on this website.
Just write to us to define the best format of collaboration.


Areas of Specialization and Portfolio
- Robotic solutions for access to dangerous and hard-to-reach areas.
- Transport systems and mobile robots.
- Robotic systems based on mining and construction machines.
- Intelligent systems and robotic systems for automatic farming and food cultivation.
- Robotic solutions for autonomous maintenance of solar power plants and other energy facilities.
Below on this page, you’ll find some of our projects.

Research, development and production of robots for inspection of vertical metal surfaces
A remotely controlled magnetic wheeled robot of a special design makes movement on vertical and horizontal metal surfaces possible. Design features are meant to assist in overcoming metal obstacles on its way.
The robot performs visual inspection (via video cameras) and carries sensors for flaw detection (checking the thickness of the protective coat and the presence of rust).
The robot is well suited to survey industrial metal tanks. Its modernization is possible, i. e. the addition of a software and hardware complex for building a 3d map of an object under study, which includes designation of detected defects.
R&D and production of wheeled and tracked inspection robots
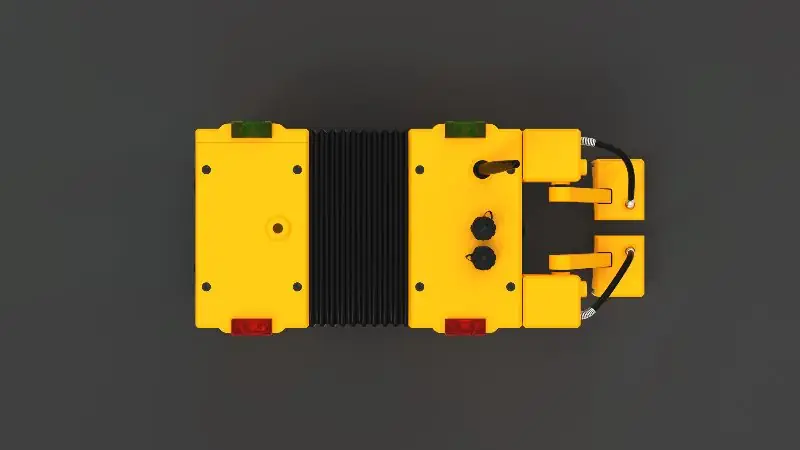
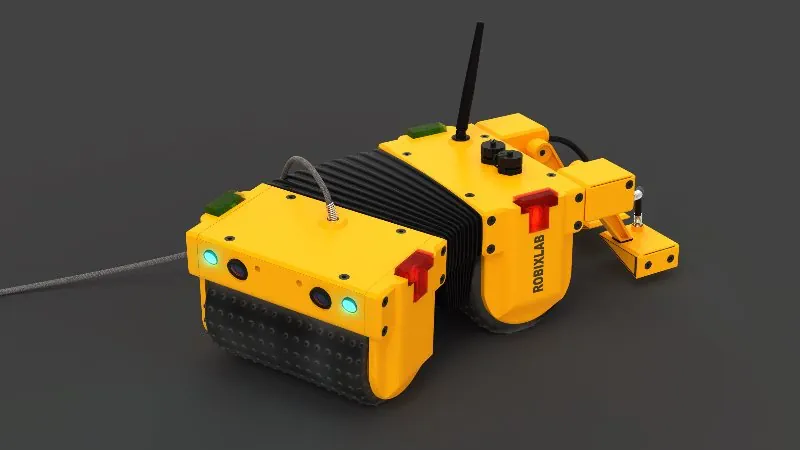
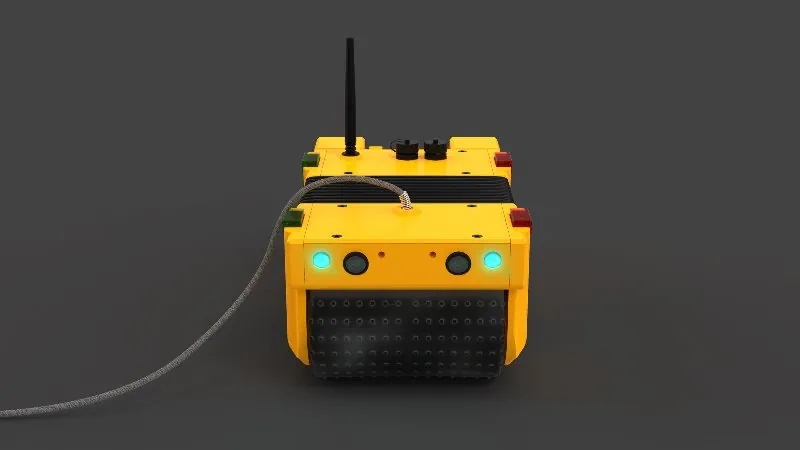
Compact inspection robots allow visual inspection of hard-to-reach cavities or facilities, including those flooded with water. Our assortment presents modifications for various geometric parameters of the objects under study, which list devices for narrow spaces with turns and those for spaces with a low height.
In order to move in basements or drainage collectors flooded with water, robots are equipped with grouser wheels, - the latter allow a vehicle to move on viscous coatings with obstacles.
We also make tracked robots to move on surfaces with a big number of obstacles on the floor . Such scheme allows them to effectively overcome wide obstructions and stairs. The configuration and shape of the tracks are developed individually for specific tasks (i. e. operating conditions, surface materials, pollution).
Robotic system for growing and harvesting tomatoes
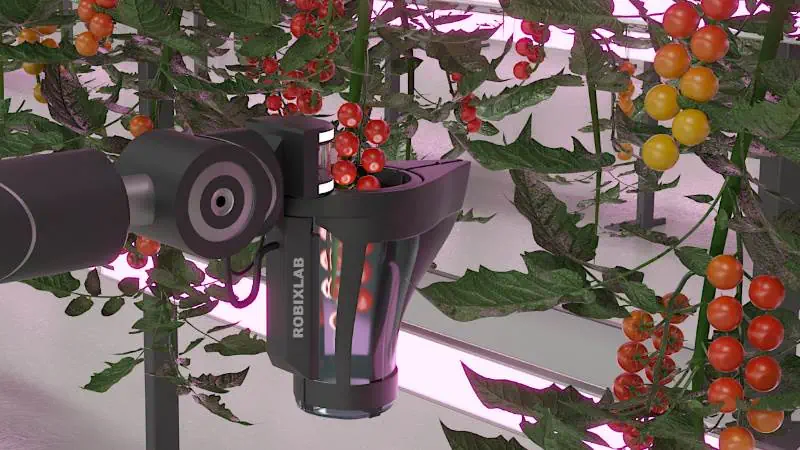
The project solves an issue of difficult working conditions for people in greenhouses who grow and harvest vegetables with a high level of ripeness ( in cases when hand-harvesting and packaging in individual containers for retail sale is required).
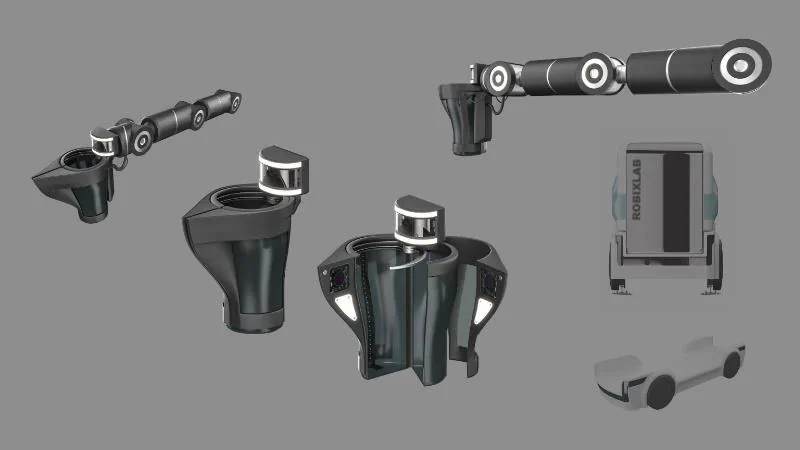
We developed the concept of a robot based on the results of a detailed study, which tackled an issue of a real activity management in greenhouses. The main element is a set of replaceable function modules placed on a collaborative manipulator sliding on a movable chassis.
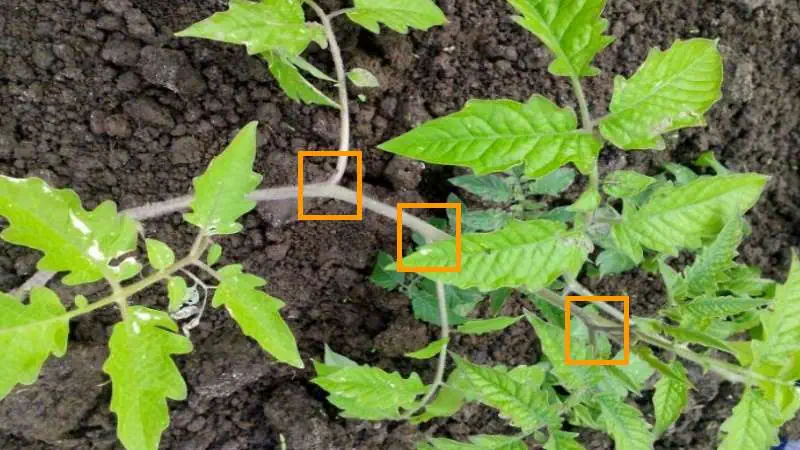
To work with tomatoes growing in clusters, we designed a special end-module with gripper and cutter, which is equipped with means for preliminary ripeness checking . In addition to this we implemented a demo version of software with a neural network . It recognizes shoot growing points on the bush in order to cut them off during the growing process.
To increase the speed capability of the robot, we have developed special equipment for "vertical farming" ( aka automated greenhouses). It is the combination of this greenhouse scheme and a robotic complex that allows you to effectively solve all the tasks of growing and harvesting. As a result, we get 85% automation, including automation of packing and palletizing operations.

Wheeled shuttles concept for plant maintenance
The territories of manufacturing facilities belonging to mining or industrial enterprises are large. To solve the task of delivering small cargoes with laboratory samples/tests/spare parts, employees tend to cover the distances either on foot or by car. We have developed a concept of medium-sized unmanned electric vehicles for the transfer of such goods, capable of operating even during snowy winters.
The concept of using this type of shuttle suggests creation of an information system that will process applications for the delivery of goods and form traffic routes automatically.
Development of the crane robotization system concept
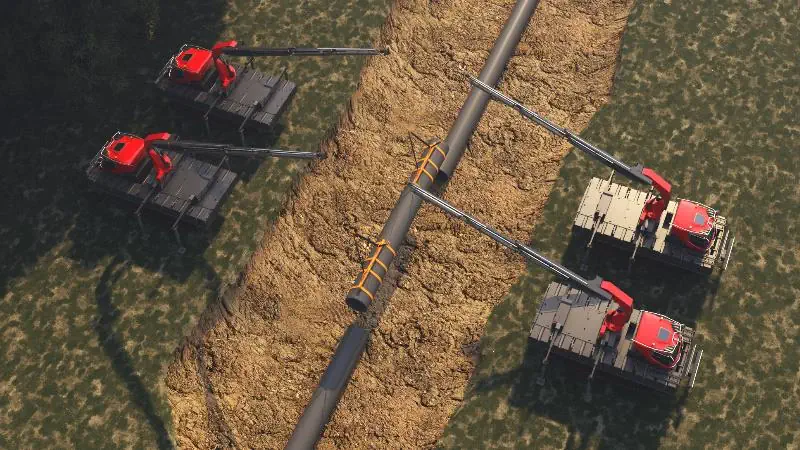
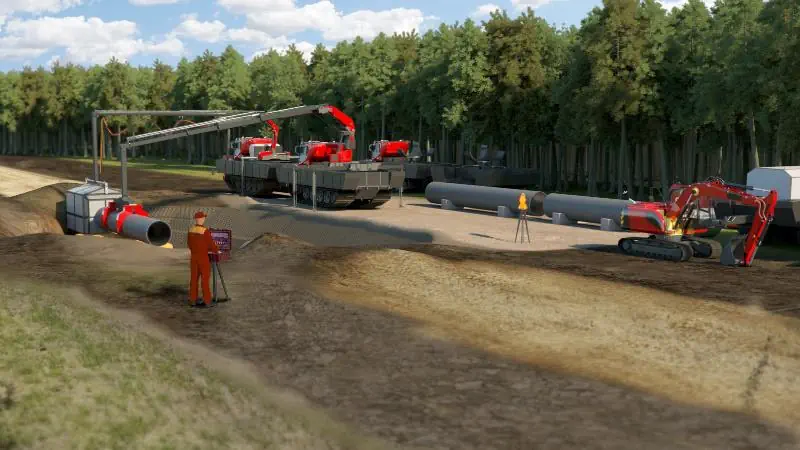
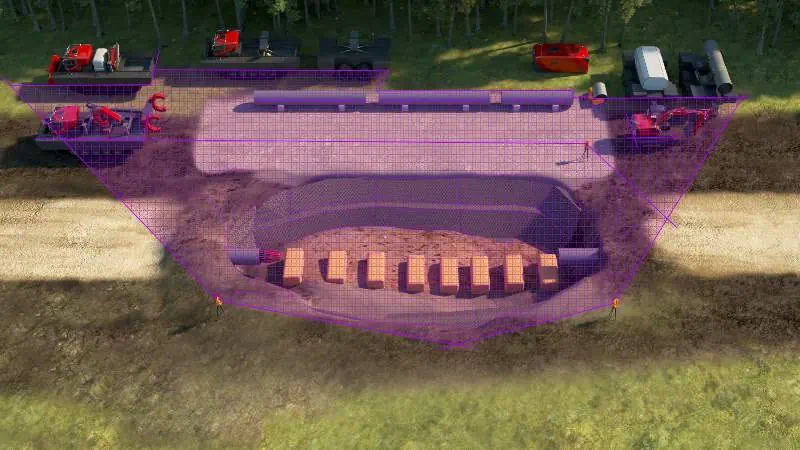
In order to perform installation or repair work in the most remote areas, it is necessary to send all the necessary specialists and operator technicians on the spot, even though their actual working time is going to be several hours, while the total duration of the trip will drag on for several days or weeks. We have worked out a concept of fitting some types of technics with remote semi-automatic control systems to optimize such problems.
This option allows a crane operator to work with machinery remotely via a satellite Internet channel. The technical complex includes sensors aimed on monitoring the crane's condition, its load, and spatial position of its elements. The movement of the crane and cargo in relation to other objects on the work site is monitored via external sensors and the computer vision system.
The second variant of this system involves combining cranes into a group with a common control unit. In this case the software package controls each crane separately to ensure the correct spatial position of a cargo being transferred.

Concept of the remote control system for the bridge crane complex
Some enterprises face the problem of machinery's low time load while operating bridge cranes, at the same time the number of such cranes in one company can be quite big.
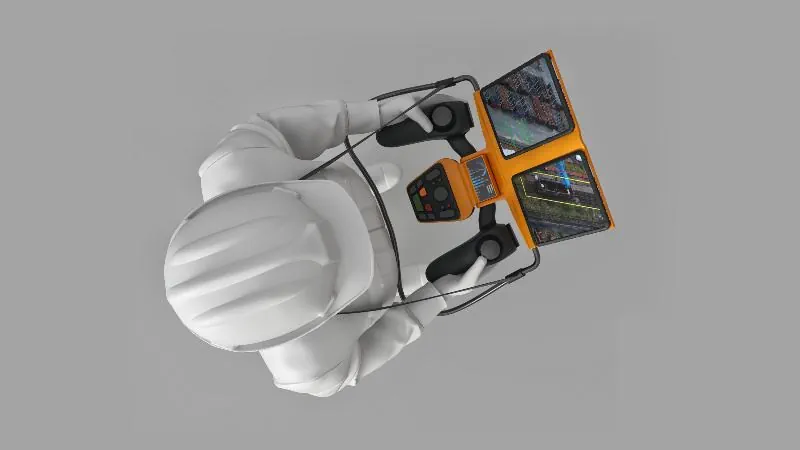
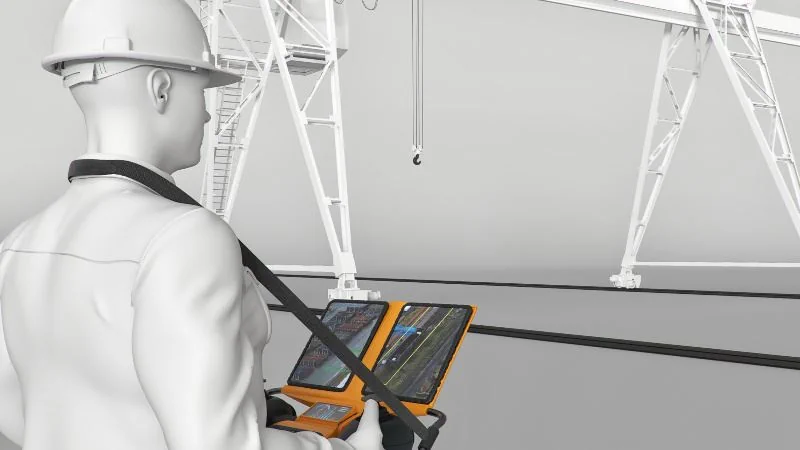
The option of placing such cranes within one territory implies using remote control (in order to spare the crane operator from taking a lift to a cabin), so that one person could be able to perform a single loading operation without wasting time. We came up with a solution to equip the crane with technical means of visual control, and simultaneously fit remote controls with augmented reality systems to simplify operator's work process. Analysis of images received from several cameras provides data for calculating the position of the supporting augmented reality elements.
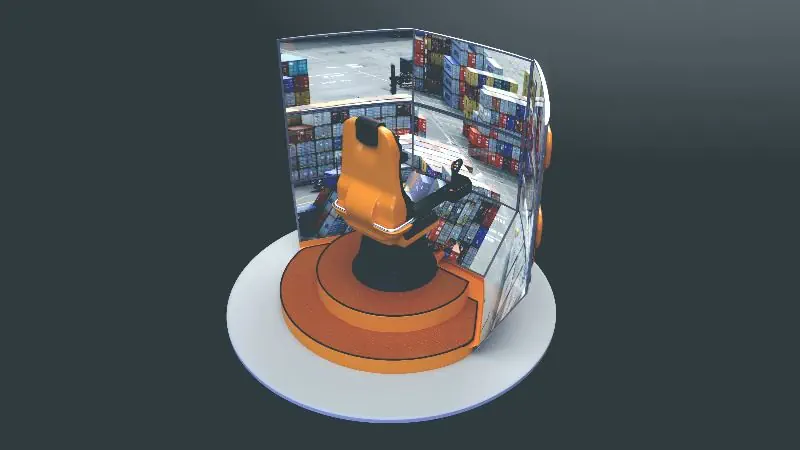
It is advisable to equip a stationary operator's workplace for remote control cranes if You place such cranes at different enterprises or deal with cranes and territories, which are rather big in size. In this case, an augmented reality system is used again, just the monitors are substantially larger. This solution increases the operator's angle of view and boosts safety.
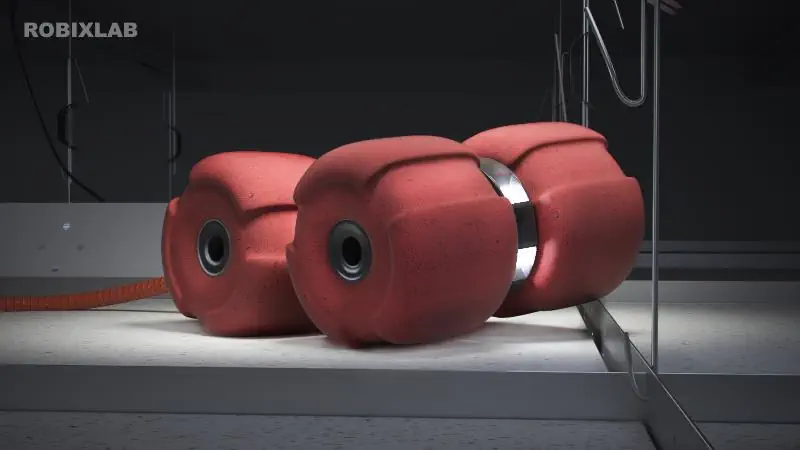
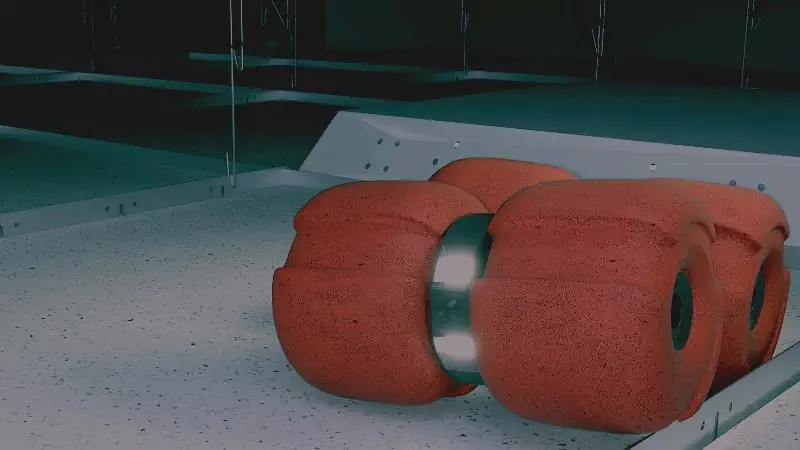
Research and development of cabling robots
Temporary communication cables routing in the ceiling space may be necessary at the stages of repairing the main standard communication lines or in case of damage their.
We have developed a special design for a remotely controlled robot to tackle these issues. Its construction is optimized for moving on surfaces and edges inside a limited ceiling space in order to pull a temporary cable there. The robot does not get stuck when passing a thin vertical edge, and its design provides contact with the surface to all wheels at the moment of overcoming the obstacle.

Design of a robot for metal tanks cleaning and painting
This is a type of a large magnetic robot that provides controlled movement on the metal walls surfaces (which are normally industrial tanks) and can carry heavy equipment and massive high-pressure hoses. It allows you to replace industrial climbers, and therefore reduce the cost of work.
The robot equipment allows You to clean surfaces from dirt and old paint, and lets You paint them over again. This is made possible by robot's ability to move heavy high-pressure hoses which are connected to ground equipment.
The list of cleaning technologies includes special options for soft abrasive blasting without dust (where only particles of the removed coating remain, which makes it a perfect replacement for sandblasting).

Design of an office robot with air disinfection function
With the advent of «covid-19» there emerged a need for air disinfection in office and exhibition premises. The mobile decontamination system can be used as a complement to stationary cleaning systems.
We developed the concept of an autonomous office robot with a built-in ultraviolet disinfector through which the surrounding air is driven. Since the specifics of the robot imply that it's prescribed specifically for exhibition and business premises, the design and convenient control interface (for determining the route of movement or obtaining reference information) become an important element.
We consciously retained the ability to interact with the interface and display all information along the route. This information is directed straight on the front panel of the robot through large displays. This is done to affect the way our robot is perceived by visitors to business events, where the robot itself becomes the object of exposure.

R&D, industrial design and production of a mobile robot for disinfection of premises and offices
We have developed a disinfection robot to sanitize in the office space. The robot combines two functional options.
The robot performs only air filtration and its UV treatment if people are currently working in the office space.
If the room is currently without people the robot performs a complete disinfection of the space using a retractable module with UV lamps. Their 360-degrees disinfection allows you to treat not only the surfaces of walls and doors, but also the working surfaces of tables, computers and other objects.
This robot concept is most relevant, since ultraviolet radiation is efficient in killing most bacteria and viruses. Stationary UV lamps in the room can't provide full light exposure of all objects, and a large number of them will affect the appearance of the room rather negatively. The mobile robot effectively solves this problem, as it allows You to perform UV sanitizer of the majority of items in the office space, including those that are obscured from ceiling lamps.

Products and systems related to robotic solutions
Robotics is rarely applied in isolation — it’s usually integrated with other technical fields. The most common combinations involve transport, manufacturing and mining machines, medical devices, equipment. and control system assistants.
If your project also requires such integration, we invite you to explore our additional areas of expertise.
Robotics Consulting Services
Our expertise is also available in a consulting format for tech R&D.
Examples of consultancy: to assess the possibilities of robotisation, to explore the feasibility of a technical solution, to make a prediction on the duration and complexity of engineering development of a robot, to estimate the economic efficiency from the creation of a technical solution, to planning the development, ideation for robotic product development companies.
Just write to us to define the best format of collaboration.
Our contacts
Let's create an amazing cutting-edge Product!
Tell us what Your business needs, and we will offer You our ideas and realisation strategies.
Serbia, Belgrade

Why does ROBIXLAB have such an unusual range of Project Topics?
Robotic solutions, Aerospace technologies, All-terrain Vehicles and Tools are unrelated only at first glance.
In our case, the connection is very strong - all of our themes are united by a central theme - robotic exploration of space and planets, which uses a variety of autonomous rovers, mining machines, food growing, satellites, and a lot of service systems and tools.
But there are also many places and tasks on planet Earth where such techniques will also be useful.